Unmanned ground vehicle
STRYKER
A heavy-duty rover for patrol, reconnaissance and forward logistics. Send it ahead into the ground people shouldn't have to cross first.
Drag to rotate
A 380 kg platform built to carry the load.
STRYKER is modular by design. The same chassis can be fitted for surveillance, cargo or inspection, and driven by an operator or sent along GPS waypoints on its own.
- Weight
- 380 kg
- Footprint
- 1.76 m × 0.80 m
- Payload
- ~400 kg on deck
- Towing
- ~1.1 tonnes
- Top speed
- 10 km/h
- Drive
- Four-wheel drive, custom 20:1 gearing
- Steering
- Ackermann with skid-turn
- Navigation
- GPS waypoint autonomy, manual override
- Environment
- Gas, temperature, humidity, tilt and pressure sensing
One rover, four ways of seeing.
Each sensor covers what the others miss. Switch between them to see how the same ground looks to STRYKER.
Picks out people and running engines by their heat, in full darkness or smoke.
Illustrative simulationDrive it, or send it.
Operators run STRYKER from a web dashboard or a handheld transmitter. Take direct control, or plot a route and let it drive the waypoints on its own.
- Tactical map
- Plan routes, drop waypoints and follow the rover's position live.
- Live telemetry
- Speed, heading, GPS, tilt and environmental readings in one view.
- Camera feeds
- Steer the pan-tilt camera and switch between thermal and low-light.
- Operator roles
- Separate access for commanders, operators and observers.
- Handheld control
- A transmitter for direct line-of-sight driving and override.
See it work.
An isometric simulation of STRYKER on four missions. Pick one, or let it play through.
Illustrative simulation, not footage. Scenery is simplified and not to scale; the rover is drawn to STRYKER's real dimensions.
Drive it yourself.
A test range in your browser. Take the controls, switch sensors, plan a route and complete four tasks, using the same features as the real STRYKER.
Tasks
Controls
- W A S D or arrows
- Drive and steer
- Q and E
- Skid-turn in place
- Space
- Brake
- C
- Switch camera
- L
- LiDAR on or off
- P, then tap the ground
- Plan a route; G drives it
- N
- Day or night
On a phone or tablet, use the joystick and the buttons.
Simplified simulation for demonstration. Handling, sensor ranges and the range itself are approximate.
Where it goes first.
STRYKER is being designed around jobs that are slow, exposed or dangerous for people to do on foot.
Perimeter and border patrol
Thermal, low-light, pan-tilt camera
Runs repeat routes through the night and streams what it sees back to the post, so patrols go out to confirm, not to search.
Forward logistics
~400 kg deck, ~1.1 t towing, GPS waypoints
Carries water, ammunition and equipment over the last stretch to a forward position, or tows a trailer that would otherwise need a vehicle and crew.
Disaster response
Thermal, LiDAR, high ground clearance
Moves through debris and flood-damaged ground after a cyclone or landslide, looking for people and mapping safe routes for rescue teams.
Hazard inspection
Flammable gas, temperature, humidity, tilt
Goes into tunnels, storage sites and industrial areas ahead of people and reports gas readings and conditions before anyone enters.
Shown to two armies.
In October 2026, soldiers of the Indian Army and the Australian Army got hands-on with STRYKER at Pangode Military Station, Thiruvananthapuram. We demonstrated it at a technology exhibition supported by Kerala Startup Mission, held during the India–Australia joint training exercise.
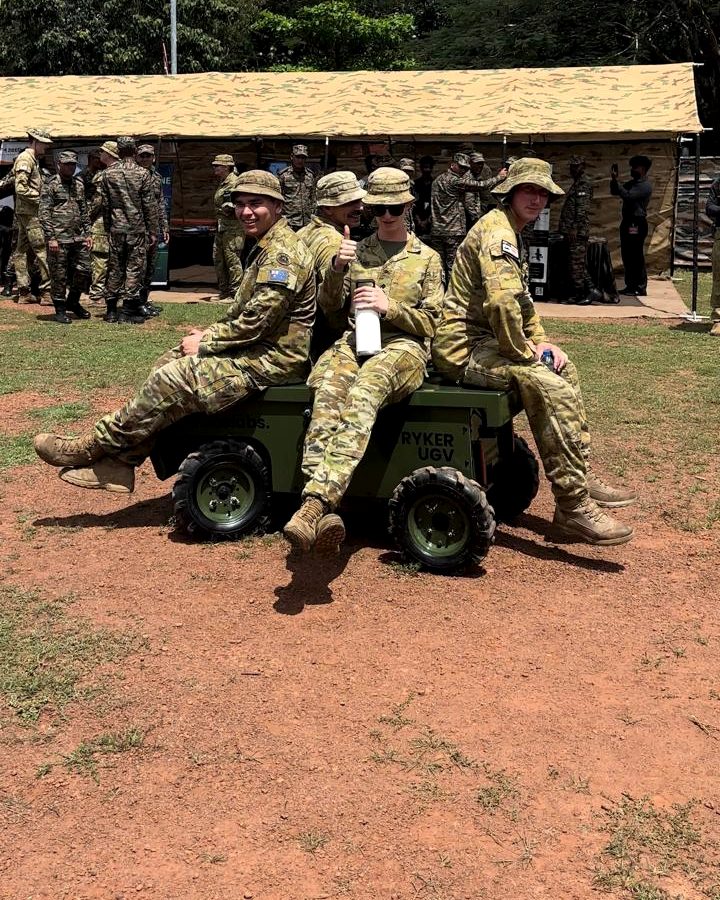
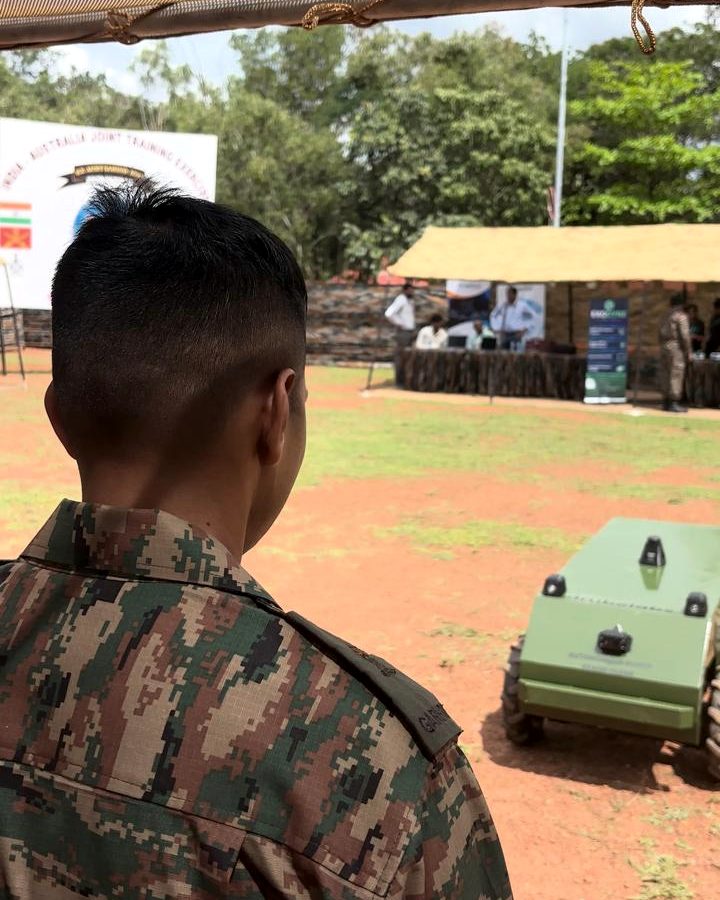
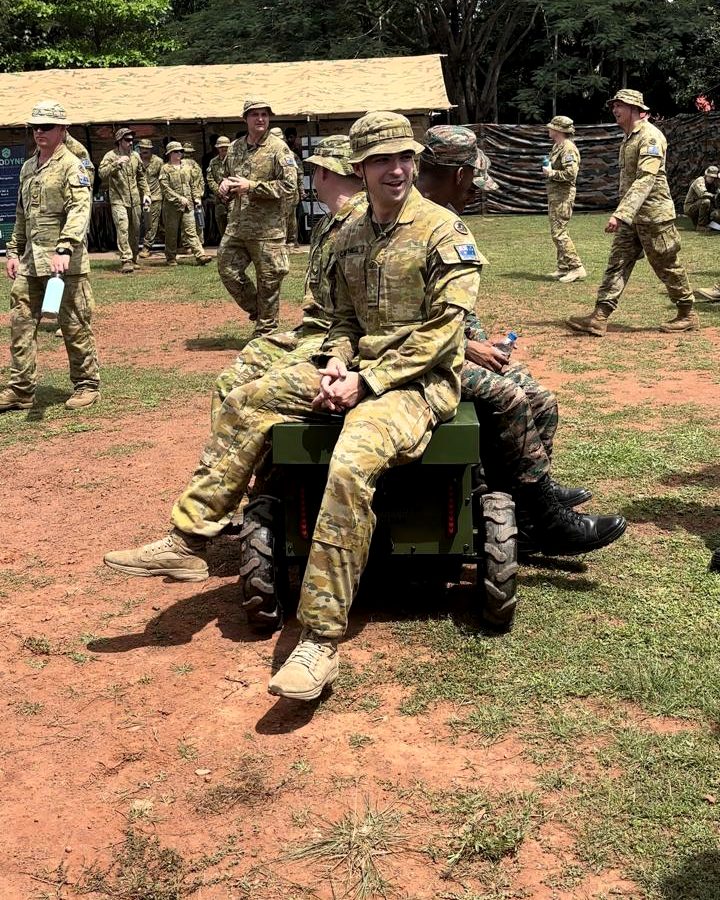
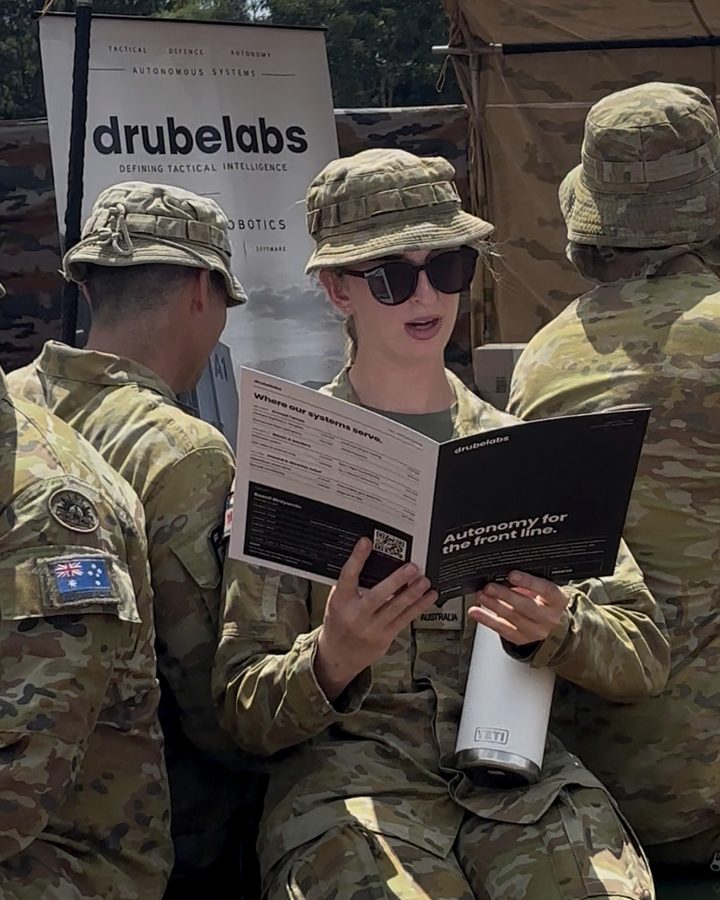
- Pangode Military StationThiruvananthapuram, Kerala
- Indian Army and Australian ArmySoldiers from both forces
- October 2026India–Australia joint training exercise
Where STRYKER is today.
STRYKER is in active development at drubelabs, Kerala Startup Mission, Kalamassery. We share progress openly as it happens.
- Prototype builtDrivetrain, power system and sensor suite integrated on the full-size chassis.
- Field testingTerrain, endurance and sensor trials. Demonstrated to the Indian Army and the Australian Army in October 2026.
- Pilot deploymentsSupervised trials with partner units on their own ground.
- ProductionConfigured builds for confirmed partners.
See STRYKER for yourself.
We brief defence, security and disaster response teams in person or online. Full specifications are shared under NDA. We're also looking for pilot partners with ground STRYKER should be tested on.